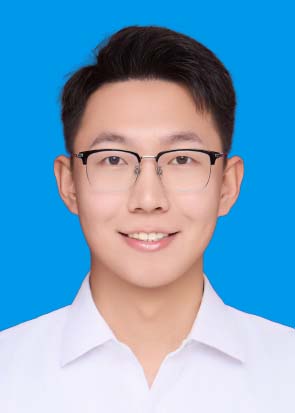
Yaofeng Cheng
Robotics · 3D Vision · Machine Learning
I work on helping robots perceive and manipulate the physical world, with a focus on transparent objects and geometry-aware grasping.
I am an engineer at the Zhejiang Humanoid Robot Innovation Center and a postdoctoral researcher at Zhejiang University. My research connects transparent object perception, 3D shape estimation and task-oriented robotic manipulation.
Research interests
Transparent perception
Recovering reliable depth and geometry for objects that challenge conventional RGB-D sensing.
Geometry-aware grasping
Using point-cloud completion and 3D shape features to generate executable 6-DoF grasps.
Task-oriented manipulation
Combining intuitive physics and learned models to choose grasps suited to the task.
Selected publications
Rethinking Transparent Object Grasping: Depth Completion with Monocular Depth Estimation and Instance Mask
Depth completion guided by instance masks and monocular depth estimation for transparent object grasping.
Citation
Cheng Y, Gao X, Zhang S, et al. Rethinking Transparent Object Grasping: Depth Completion with Monocular Depth Estimation and Instance Mask[J]. IEEE Robotics and Automation Letters, vol. 11, no. 5, pp. 5510-5517, May 2026.
PCF-Grasp: Converting Point Completion to Geometry Feature to Enhance 6-DoF Grasp
Using completed point clouds as geometric features to improve 6-DoF grasp generation from partial observations.
A2G: Leveraging Intuitive Physics for Force-Efficient Robotic Grasping
Learning intuitive physics from point clouds to choose force-efficient grasps for object manipulation.
Citation
Y. Cheng et al., "A2G: Leveraging Intuitive Physics for Force-Efficient Robotic Grasping," in IEEE Robotics and Automation Letters, vol. 9, no. 7, pp. 6376-6383, July 2024, doi: 10.1109/LRA.2024.3401675.
Background
I received my Ph.D. in Mechatronics Engineering from Harbin Institute of Technology, conducting research at the State Key Laboratory of Robotics and System under the supervision of Fusheng Zha. During my Ph.D., I undertook a CSC-supported research exchange at the University of Liverpool with Chenguang Yang. I received my B.Eng. from Wuhan University of Technology.